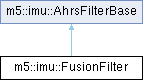
Adapter around the vendored x-io Fusion AHRS algorithm (x-io Technologies, MIT license; see src/imu/filter/third_party/fusion) More...
#include <fusion.hpp>
Public Member Functions | |
| virtual void | reset () override |
| Reset the internal attitude estimate (and any filter state) to identity. | |
| virtual void | update (const float dt, const float accel[3], const float gyro[3], const float *mag) override |
| Fuse one IMU sample into the attitude estimate. | |
| virtual void | quaternion (float &w, float &x, float &y, float &z) const override |
| Current fused attitude. | |
| bool | writeGain (const float gain) |
| Set the AHRS feedback gain (FusionAhrsSettings.gain) | |
| float | readGain () const |
| Current feedback gain. | |
| bool | startupInProgress () const |
| Whether Fusion's startup ramp is still in progress. | |
| bool | writeQuaternion (const float w, const float x, const float y, const float z) |
| Overwrite the current attitude estimate directly. | |
Detailed Description
Adapter around the vendored x-io Fusion AHRS algorithm (x-io Technologies, MIT license; see src/imu/filter/third_party/fusion)
Fusion's own attitude/feedback algorithm is used as-is (this adapter performs no re-derivation of the underlying math, unlike ComplementaryFilter/MadgwickFilter/ MahonyFilter/EKFFilter). The adapter's job is limited to the AhrsFilterBase <-> Fusion API boundary:
- Units: Fusion's
FusionAhrsUpdate()/FusionAhrsUpdateNoMagnetometer()already take gyroscope in dps, accelerometer in G and magnetometer in "any calibrated units" (see FusionAhrs.h), matching this repository's unit contract (filter_base.hpp) exactly – no scaling is applied here. - Earth axes convention:
FusionAhrsSettings.conventionis fixed toFusionConventionNwu(North(X)/West(Y)/Up(Z)) in the constructor, which is the only one of Fusion's three conventions (Nwu/Enu/Ned) consistent with this repository's world frame (filter_base.hpp): FusionConventionNed's earth Z axis is "down", which contradicts a static/level unit reading accel = (0,0,+1) G; that leaves Nwu and Enu, both earth-Z-up, differing only in which world axis the horizontal magnetometer reference aligns to (X for Nwu, Y for Enu) – filter_base.hpp's mag table places that reference along world +X at yaw = 0, which is Nwu's "North" (X) axis. (This is also Fusion's own library default,fusionAhrsDefaultSettings.convention.) The Fusion quaternion is read back viaFusionAhrsGetQuaternion()component-for-component (w,x,y,z) with no reordering or sign flip: Fusion's ownHalfGravity()formula for Nwu/Enu (see FusionAhrs.c) is algebraically identical to the predicted-gravity-in- body-frame expansion this repository's other filters derive fromm5::math::Quaternion::rotate()/fromEuler()(see e.g. MahonyFilter::update()), so the two quaternion representations already agree. - Startup ramp: Fusion always starts (on
FusionAhrsInitialise()/FusionAhrsRestart(), i.e. also afterreset()) with a high gain (10.0) that ramps down to the configured gain over a fixed 3-second window (STARTUP_PERIODin FusionAhrs.c) – this is Fusion's own behavior, not something this adapter can tune. It also meansFusionAhrsUpdateNoMagnetometer()forces the yaw heading to 0 on every call while that window is open, so gyro-only yaw integration only becomes observable once the filter has been running (real, cumulative dt) for more than 3 seconds; see test/native/test_filter/fusion_test.cpp for how the shared scenarios account for this.
Member Function Documentation
◆ quaternion()
|
overridevirtual |
Current fused attitude.
- Parameters
-
[out] w Quaternion scalar part [out] x Quaternion vector part X [out] y Quaternion vector part Y [out] z Quaternion vector part Z
Implements m5::imu::AhrsFilterBase.
◆ reset()
|
overridevirtual |
Reset the internal attitude estimate (and any filter state) to identity.
Implements m5::imu::AhrsFilterBase.
◆ startupInProgress()
| bool m5::imu::FusionFilter::startupInProgress | ( | ) | const |
Whether Fusion's startup ramp is still in progress.
True for the first 3 seconds (of summed update() dt) after construction or reset(), with the default gain; a gain of 0 or of 10 (Fusion's startup gain) or more ends it on the first update(). During that window Fusion corrects with a high gain and, on a no-magnetometer update(), holds the yaw heading at 0, so a rotation made then is not reflected.
◆ update()
|
overridevirtual |
Fuse one IMU sample into the attitude estimate.
- Parameters
-
dt Time elapsed since the previous update(), in seconds accel Accelerometer reading (G), body frame, X/Y/Z gyro Gyroscope reading (dps), body frame, X/Y/Z mag Magnetometer reading (uT), body frame, X/Y/Z; pass nullptrfor 6-axis (accel+gyro only) operation
Implements m5::imu::AhrsFilterBase.
◆ writeGain()
| bool m5::imu::FusionFilter::writeGain | ( | const float | gain | ) |
Set the AHRS feedback gain (FusionAhrsSettings.gain)
- Parameters
-
gain Feedback gain, must be >= 0 (0 disables accelerometer/magnetometer outlier rejection as well as feedback correction speed limiting – see Fusion's own FusionAhrsSetSettings())
- Returns
- False (and keeps the previous value) if gain is negative
◆ writeQuaternion()
| bool m5::imu::FusionFilter::writeQuaternion | ( | const float | w, |
| const float | x, | ||
| const float | y, | ||
| const float | z ) |
Overwrite the current attitude estimate directly.
Not part of AhrsFilterBase; intended for seeding a known starting attitude (e.g. tests, or resuming from a previously stored orientation).
- Parameters
-
w W component of the quaternion x X component of the quaternion y Y component of the quaternion z Z component of the quaternion
- Returns
- False (and keeps the previous value) if the resulting quaternion is (near) zero
