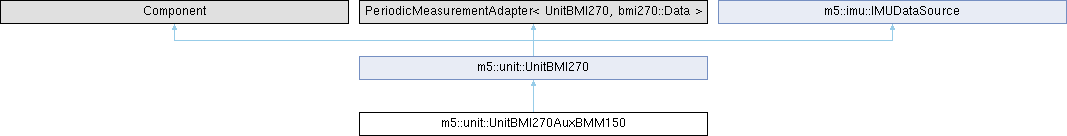
BMI270 that switches on its auxiliary (AUX) interface and drives a BMM150 through it. More...
#include <unit_bmi270_aux_bmm150.hpp>
Classes | |
| struct | config_t |
| Settings for begin(), extending the base with the magnetometer's own. More... | |
Public Member Functions | |
| UnitBMI270AuxBMM150 (const uint8_t addr=DEFAULT_ADDRESS) | |
| Construct with the BMI270's I2C address (the AUX BMM150 sits behind the bridge) | |
| virtual | ~UnitBMI270AuxBMM150 () |
| Destructor. | |
| virtual bool | begin () override |
| Seed the magnetometer's live state from config_t, then run the base begin() | |
| bool | sleep () override |
| Suspend the chip, parking the AUX BMM150 first. | |
Settings | |
| config_t | config () const |
| Gets the configuration. | |
| void | config (const config_t &cfg) |
| Set the configuration. | |
IMUDataSource | |
| virtual m5::imu::Capability | imuSpec () const override |
| Capability of this unit. | |
| virtual void | imuConvertParam (m5::imu::imu_convert_param_t &out) const override |
| Gets the conversion parameters for raw IMU data. | |
AUX magnetometer setting (stop periodic measurement first) | |
| bool | writeAuxMagPreset (const bmm150::Preset preset) |
| Write the accuracy/power preset of the AUX BMM150. | |
| bool | writeAuxMagRepetition (const uint8_t rep_xy, const uint8_t rep_z) |
| Write the repetition (oversampling) of the AUX BMM150. | |
| bool | readAuxMagRepetition (uint8_t &rep_xy, uint8_t &rep_z) const |
| Read the repetition (oversampling) the AUX BMM150 is configured with. | |
 Public Member Functions inherited from m5::unit::UnitBMI270 | |
| UnitBMI270 (const uint8_t addr=DEFAULT_ADDRESS) | |
| Construct with the I2C address the chip will answer on. | |
| virtual | ~UnitBMI270 () |
| Destructor. | |
| virtual void | update (const bool force=false) override |
| Update the unit. | |
| config_t | config () const |
| Gets the configuration. | |
| void | config (const config_t &cfg) |
| Set the configuration. | |
| bool | writeAccelRange (const bmi270::AccelRange range) |
| Write the accelerometer range. | |
| bool | writeGyroRange (const bmi270::GyroRange range) |
| Write the gyroscope range. | |
| bool | readAccelRange (bmi270::AccelRange &range) |
| Read the accelerometer range from the device (REG_ACC_RANGE bits[1:0]) | |
| bool | readGyroRange (bmi270::GyroRange &range) |
| Read the gyroscope range from the device (REG_GYR_RANGE bits[2:0]) | |
| bool | writeAccelODR (const bmi270::AccelODR odr) |
| Write the accelerometer output data rate. | |
| bool | writeGyroODR (const bmi270::GyroODR odr) |
| Write the gyroscope output data rate. | |
| bool | readAccelODR (bmi270::AccelODR &odr) |
| Read the accelerometer output data rate from the device (REG_ACC_CONF bits[3:0]) | |
| bool | readGyroODR (bmi270::GyroODR &odr) |
| Read the gyroscope output data rate from the device (REG_GYR_CONF bits[3:0]) | |
| bool | softReset () |
| Soft reset (REG_CMD CMD_SOFTRESET), then re-run the mandatory post-reset initialization (config blob re-upload), leaving the chip initialized but unconfigured and stopped. | |
| bool | startPeriodicMeasurement (const bmi270::AccelRange accel_range, const bmi270::GyroRange gyro_range, const bmi270::AccelODR accel_odr, const bmi270::GyroODR gyro_odr, const bmi270::FilterPerf accel_filter_perf, const bmi270::AccelBwp accel_bwp, const bmi270::FilterPerf gyro_filter_perf, const bmi270::GyroBwp gyro_bwp) |
| Start periodic measurement. | |
| bool | startPeriodicMeasurement () |
| Start periodic measurement in the current settings. | |
| bool | stopPeriodicMeasurement () |
| Stop periodic measurement. | |
| bool | wakeup () override |
| Resume the chip from sleep() | |
| virtual m5::imu::Capability | readImuRaw (m5::imu::imu_raw_data_t &out) override |
| Read the latest raw IMU data. | |
Protected Types | |
| enum class | AuxDetect : uint8_t { Unknown , Absent , Present } |
Protected Member Functions | |
| virtual bool | start_periodic_measurement (const bmi270::AccelRange accel_range, const bmi270::GyroRange gyro_range, const bmi270::AccelODR accel_odr, const bmi270::GyroODR gyro_odr, const bmi270::FilterPerf accel_filter_perf, const bmi270::AccelBwp accel_bwp, const bmi270::FilterPerf gyro_filter_perf, const bmi270::GyroBwp gyro_bwp) override |
| virtual bool | read_sensor_burst (bmi270::Data &d) override |
| One 20 byte burst covering mag + accel + gyro, instead of the base's 12 byte accel/gyro read. | |
| bool | setup_aux_bmm150 () |
| bool | aux_enter_setup_mode () |
| bool | aux_detect_bmm150 () |
| bool | aux_enter_data_mode () |
| bool | aux_wait_ready () |
| bool | aux_write_register8 (const uint8_t reg, const uint8_t val) |
| bool | aux_read_register8 (const uint8_t reg, uint8_t &out) |
| bool | aux_read_burst8 (const uint8_t bmm150_reg, std::array< uint8_t, 8 > &out) |
| bool | aux_read_trim (bmm150::trim_t &trim) |
| Protected Member Functions inherited from m5::unit::UnitBMI270 | |
| bool | start_periodic_measurement () |
| bool | stop_periodic_measurement () |
| bool | read_measurement (bmi270::Data &d) |
| bool | write_register8_verified (const uint8_t reg, const uint8_t val) |
| bool | read_register8_quiet (const uint8_t reg, uint8_t &out) |
| bool | recover_wedged_interface (const uint8_t id) |
| bool | upload_config () |
| M5_UNIT_COMPONENT_PERIODIC_MEASUREMENT_ADAPTER_HPP_BUILDER (UnitBMI270, bmi270::Data) | |
Detailed Description
BMI270 that switches on its auxiliary (AUX) interface and drives a BMM150 through it.
The BMI270's AUX interface is a general-purpose I2C master built into the chip – the datasheet calls it a "master interface hub for 1 I2C AUX sensor (e.g. ext. magnetometer, pressure)". This class implements one specific target, a Bosch BMM150: it addresses 0x10, checks for chip ID 0x32, reads that part's factory trim and drives its repetition/opmode registers. The name records that choice, since a different AUX target would need a different driver.
Which class to instantiate is a property of the board, not of the chip:
- This class turns the interface on and probes for the BMM150. CoreS3 / AtomS3R / Mini IMU-Pro (U171) wire one there. Built-in IMUs in general should use it – the probe adapts to whatever the host actually carries, with no board table to keep up to date.
- The plain UnitBMI270 never touches the interface. Use it where the wiring makes enabling it unsafe or pointless: on UnitDoF9 / UnitDoF10 the AUX pins are tied to the main I2C bus, so enabling them turns the BMI270 into a second bus master and the bus locks up until the unit is power-cycled; on UnitDoF6 there is simply no magnetometer.
Naming a chip here does not promise one is present – that is only known at runtime. On a host without a BMM150 (Capsule, StickS3, Core2 v1.3, ...) the probe finds nothing, the interface is switched back off, and the unit runs as a plain 6-axis BMI270. imuSpec() reports Mag only once a BMM150 has actually answered.
- Note
- The BMM350 in UnitDoF9 / UnitDoF10 / Unit BMM350 (U231) sits on the main bus, not on this interface, and is driven by UnitBMM350 instead
- The bridge polls the BMM150 at a fixed 25Hz – the only rate the BMI270's aux_odr field and the BMM150's normal mode both offer – which bounds its usable oversampling; see config_t::aux_mag_preset
Member Enumeration Documentation
◆ AuxDetect
|
strongprotected |
Whether this board carries a BMM150 on the interface. Answered once, then remembered: re-running the detection below on every start costs a BMM150 soft reset plus three trim bursts, and the answer cannot change while the unit stays powered
| Enumerator | |
|---|---|
| Unknown | Not probed yet, or invalidated by begin()/sleep() |
| Absent | Nothing answered on the interface; it is left switched off. |
| Present | A BMM150 answered and _mag_trim holds its factory trim. |
Constructor & Destructor Documentation
◆ UnitBMI270AuxBMM150()
|
explicit |
Construct with the BMI270's I2C address (the AUX BMM150 sits behind the bridge)
- Parameters
-
[in] addr I2C address (defaults to the chip's factory address)
Member Function Documentation
◆ begin()
|
overridevirtual |
Seed the magnetometer's live state from config_t, then run the base begin()
Reimplemented from m5::unit::UnitBMI270.
◆ config() [1/2]
|
inline |
Gets the configuration.
- Returns
- Current configuration
◆ config() [2/2]
|
inline |
Set the configuration.
- Parameters
-
[in] cfg Configuration
- Note
- The inherited fields stay in the base's own storage, so reading them back through a UnitBMI270 reference always agrees with what was set here
◆ imuConvertParam()
|
overridevirtual |
Gets the conversion parameters for raw IMU data.
- Parameters
-
[out] out Conversion parameters
Reimplemented from m5::unit::UnitBMI270.
◆ imuSpec()
|
inlineoverridevirtual |
Capability of this unit.
- Returns
- Accel | Gyro | Temp, plus Mag once an AUX BMM150 has been detected in startPeriodicMeasurement()
Reimplemented from m5::unit::UnitBMI270.
◆ read_sensor_burst()
|
overrideprotectedvirtual |
One 20 byte burst covering mag + accel + gyro, instead of the base's 12 byte accel/gyro read.
Reimplemented from m5::unit::UnitBMI270.
◆ readAuxMagRepetition()
| bool m5::unit::UnitBMI270AuxBMM150::readAuxMagRepetition | ( | uint8_t & | rep_xy, |
| uint8_t & | rep_z ) const |
Read the repetition (oversampling) the AUX BMM150 is configured with.
- Parameters
-
[out] rep_xy Value of REG_REP_XY [out] rep_z Value of REG_REP_Z
- Returns
- True if successful
- Note
- Returns the value this unit applies to the magnetometer, not a fresh register read: the BMM150 is only reachable while the bridge is in setup mode, which periodic measurement is not
◆ sleep()
|
overridevirtual |
Suspend the chip, parking the AUX BMM150 first.
- Returns
- True if successful
The magnetometer keeps running on its own once the bridge is gone, so it is put into its own suspend mode before the BMI270 powers down. Otherwise identical to UnitBMI270::sleep()
Reimplemented from m5::unit::UnitBMI270.
◆ start_periodic_measurement()
|
overrideprotectedvirtual |
Reimplemented from m5::unit::UnitBMI270.
◆ writeAuxMagPreset()
| bool m5::unit::UnitBMI270AuxBMM150::writeAuxMagPreset | ( | const bmm150::Preset | preset | ) |
Write the accuracy/power preset of the AUX BMM150.
- Parameters
-
[in] preset Preset
- Returns
- True if successful
- Note
- Convenience wrapper around writeAuxMagRepetition() with the preset's repetition values
◆ writeAuxMagRepetition()
| bool m5::unit::UnitBMI270AuxBMM150::writeAuxMagRepetition | ( | const uint8_t | rep_xy, |
| const uint8_t | rep_z ) |
Write the repetition (oversampling) of the AUX BMM150.
- Parameters
-
[in] rep_xy Value of REG_REP_XY (repetitions = 1 + 2 * rep_xy) [in] rep_z Value of REG_REP_Z (repetitions = 1 + rep_z)
- Returns
- True if successful
- Warning
- Fails while periodic measurement is running, and fails for a pair the bridge's fixed 25Hz poll cannot complete in time (bmm150::repetition_fits()); unlike a stand-alone UnitBMM150 there is no slower rate to fall back on, so the ceiling here is absolute
- Note
- The value is applied to the magnetometer by the next startPeriodicMeasurement(). While measurement is stopped the bridge is not in a state where the BMM150's registers can be reached, so nothing is written to it here
