Loading...
Searching...
No Matches
m5::unit::UnitMPU6050 Class Reference
TDK InvenSense MPU-6050 6-axis IMU (accel + gyro + temp). WHO_AM_I 0x68. More...
#include <unit_mpu6050.hpp>
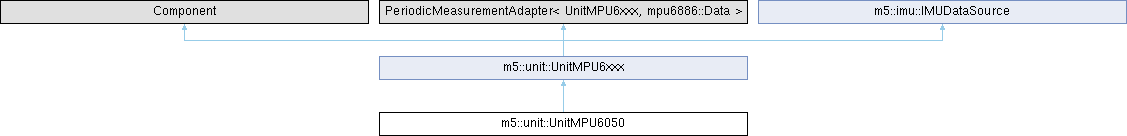
Inheritance diagram for m5::unit::UnitMPU6050:
Public Member Functions | |
| UnitMPU6050 (const uint8_t addr=DEFAULT_ADDRESS) | |
 Public Member Functions inherited from m5::unit::UnitMPU6xxx | |
| virtual bool | begin () override |
| Begin the unit. | |
| virtual void | update (const bool force=false) override |
| Update the unit. | |
| config_t | config () const |
| Gets the configuration. | |
| void | config (const config_t &cfg) |
| Set the configuration. | |
| bool | writeAccelRange (const mpu6886::AccelRange range) |
| Write the accelerometer range. | |
| bool | writeGyroRange (const mpu6886::GyroRange range) |
| Write the gyroscope range. | |
| bool | readAccelRange (mpu6886::AccelRange &range) |
| Read the accelerometer range from the device (REG_ACCEL_CONFIG bits[4:3]) | |
| bool | readGyroRange (mpu6886::GyroRange &range) |
| Read the gyroscope range from the device (REG_GYRO_CONFIG bits[4:3]) | |
| bool | writeSampleRateDiv (const uint8_t div) |
| Write the sample rate divider. | |
| bool | readSampleRateDiv (uint8_t &div) |
| Read the sample rate divider from the device (REG_SMPLRT_DIV) | |
| bool | writeDlpf (const mpu6886::Dlpf dlpf) |
| Write the digital low-pass filter bandwidth. | |
| bool | readDlpf (mpu6886::Dlpf &dlpf) |
| Read the digital low-pass filter bandwidth from the device (REG_CONFIG bits[2:0]) | |
| bool | softReset () |
| Soft reset (REG_PWR_MGMT_1 DEVICE_RESET), leaving the chip initialized but unconfigured and stopped. | |
| bool | startPeriodicMeasurement (const mpu6886::AccelRange accel_range, const mpu6886::GyroRange gyro_range, const mpu6886::Dlpf dlpf, const uint8_t sample_rate_div) |
| Start periodic measurement. | |
| bool | startPeriodicMeasurement () |
| Start periodic measurement in the current settings. | |
| bool | stopPeriodicMeasurement () |
| Stop periodic measurement. | |
| bool | sleep () override |
| Put the chip to sleep (REG_PWR_MGMT_1 SLEEP) | |
| bool | wakeup () override |
| Wake the chip from sleep() | |
| virtual m5::imu::Capability | imuSpec () const override |
| Capability of this unit. | |
| virtual m5::imu::Capability | readImuRaw (m5::imu::imu_raw_data_t &out) override |
| Read the latest raw IMU data. | |
| virtual void | imuConvertParam (m5::imu::imu_convert_param_t &out) const override |
| Gets the conversion parameters for raw IMU data. | |
Protected Member Functions | |
| bool | accepts_whoami (const uint8_t id) const override |
| Accepted WHO_AM_I id(s) for this chip; begin() rejects the device unless this returns true. | |
| float | temperature_res () const override |
| Temperature conversion: degC per LSB (imu_convert_param_t::temp_res) | |
| float | temperature_offset () const override |
| Temperature conversion: degC offset (imu_convert_param_t::temp_offset) | |
| Protected Member Functions inherited from m5::unit::UnitMPU6xxx | |
| UnitMPU6xxx (const uint8_t addr=DEFAULT_ADDRESS) | |
| Protected: UnitMPU6xxx is abstract, constructed only by concrete derived chips. | |
| virtual bool | start_periodic_measurement (const mpu6886::AccelRange accel_range, const mpu6886::GyroRange gyro_range, const mpu6886::Dlpf dlpf, const uint8_t sample_rate_div) |
| Virtual: UnitMPU9250 layers its aux-bypass re-open on top (the config write here includes INT_PIN_CFG=0xC0, which closes the bypass) | |
| bool | start_periodic_measurement () |
| bool | stop_periodic_measurement () |
| bool | read_measurement (mpu6886::Data &d) |
| bool | write_register8_verified (const uint8_t reg, const uint8_t val) |
| M5_UNIT_COMPONENT_PERIODIC_MEASUREMENT_ADAPTER_HPP_BUILDER (UnitMPU6xxx, mpu6886::Data) | |
Detailed Description
TDK InvenSense MPU-6050 6-axis IMU (accel + gyro + temp). WHO_AM_I 0x68.
Member Function Documentation
◆ accepts_whoami()
|
inlineoverrideprotectedvirtual |
Accepted WHO_AM_I id(s) for this chip; begin() rejects the device unless this returns true.
Implements m5::unit::UnitMPU6xxx.
◆ temperature_offset()
|
inlineoverrideprotectedvirtual |
Temperature conversion: degC offset (imu_convert_param_t::temp_offset)
Implements m5::unit::UnitMPU6xxx.
◆ temperature_res()
|
inlineoverrideprotectedvirtual |
Temperature conversion: degC per LSB (imu_convert_param_t::temp_res)
Implements m5::unit::UnitMPU6xxx.
